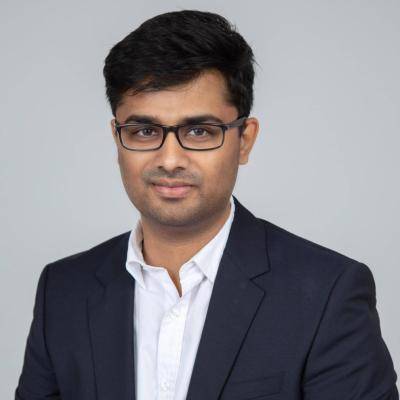
person Yashwanth Kumar Nakka
work Assistant Professor, Daniel Guggenheim School of Aerospace Engineering, Georgia Tech
calendar_month October 30, 2026
schedule 11:00 am - 12:00 pm
pin_drop TSRB Auditorium (118)
(Hosted by DCL)
Decision Making Under Uncertainty for Aerospace Robots: From Chance Constraints to Perception-Based Safety and Collaborative Sensing
Abstract
Spacecraft and planetary robots must operate under uncertain dynamics, environmental disturbances, and physical constraints. At the Aerospace Stochastic Robotics and Exploration (AstroX) Lab at Georgia Tech, we develop planning, estimation, and control methods for these systems, both individually and in teams. In this talk, I will address a central question: how can a robot account for uncertainty when planning a motion and maintain safety while executing it? I will discuss stochastic trajectory optimization and feedback control methods that connect these two stages, making explicit the assumptions behind their guarantees and the limits of those guarantees.
I will begin with convex formulations of chance-constrained optimal control, showing how uncertainty and allowable risk together shape trajectory feasibility and control effort. I will then present model predictive control with barrier-defined terminal sets, which reduces the conservatism of conventional terminal constraints while preserving recursive feasibility under the stated assumptions. Next, I will consider how environmental perception enters safety-critical control through filters that construct collision constraints directly from 3D Gaussian-splatting maps while accounting for nonlinear quadrotor dynamics and actuator limits. Throughout, I will distinguish probabilistic constraint satisfaction, recursive feasibility, and invariance, and explain what each formulation guarantees and under which conditions. These methods will be illustrated through experimental investigations on quadrotor, rover, and spacecraft testbeds. I will close with multi-spacecraft on-orbit inspection and formation-constrained planning for multi-rover lunar surveys, discussing how coordinated motion and sensing extend these questions from individual robots to teams.
Biography
Yashwanth Kumar Nakka is an Assistant Professor in the Daniel Guggenheim School of Aerospace Engineering at Georgia Tech and Director of the Aerospace Stochastic Robotics and Exploration (AstroX) Lab. His research focuses on planning, estimation, and control under uncertainty for spacecraft and planetary robots, with an emphasis on safety-critical autonomy and multi-robot systems.
He received his Ph.D. in Space Engineering from the California Institute of Technology in 2021 and holds master’s degrees from Caltech and the University of Illinois Urbana-Champaign. Before joining Georgia Tech, he was a Robotics Technologist at NASA’s Jet Propulsion Laboratory, where he contributed to planning, control, and estimation for the CADRE, EELS, and DARPA LINC projects. He previously served as a Scientist/Engineer at the Indian Space Research Organization, working on the GSAT-15 and GSAT-16 missions.
Dr. Nakka is a James G. and Dee H. Pope Faculty Fellow and a 2025 Space Fellow at Georgia Tech. His honors include the NASA Group Achievement Award for EELS (2026), the JPL CADRE Team Award (2024), and the AIAA Guidance, Navigation, and Control Best Student Paper Award (2021). He serves as an Associate Editor for IEEE Robotics and Automation Letters.